Unitree G1 - Comp | Robot humanoidalny | Wersja turniejowa
Warianty: Football
Robot humanoidalny klasy turniejowej do RoboCup: szybka lokomocja i wysoka stabilność
G1-Comp to humanoid o masie 35 kg, 25–45 DOF i momencie obrotowym w kolanie 120 Nm, co umożliwia szybkie przyspieszanie, stabilne skręcanie i odzyskiwanie równowagi po uderzeniu. Składana konstrukcja pozwala zmniejszyć wymiary z 1320×450×200 mm do 690×450×300 mm, co ułatwia transport i zachowanie zwinności na boisku. Osiąga prędkość sprintu 3,3 m/s i utrzymuje stabilność ±2° w zakresie pochylenia i przechylenia na nierównym boisku. LiDAR LIVOX MID-360, kamera głębi RealSense i detekcja stadionu oparta na YOLO11 umożliwiają mapowanie, śledzenie celów i lokalizację przeciwników.
Ekosystem oprogramowania obejmuje moduł Jetson Orin NX o wydajności obliczeniowej 100–157 TOPS dla AI, framework RL unitree_rl_gym, pipeline'y symulacyjne Isaac Gym i Mujoco oraz dedykowany SDK RoboCup udostępniający API do sterowania ruchem, pozycjonowania przestrzennego, przetwarzania obrazu i integracji z przepisami turniejowymi. Złącza z podwójnym enkoderem zwiększają precyzję, a akumulatory z szybką wymianą zapewniają około 2 godzin ciągłej pracy i obsługują szybkie ładowanie.
Idealny dla drużyn startujących w RoboCup, grup badawczych zajmujących się lokomocją, laboratoriów uczących się przez wzmacnianie oraz deweloperów potrzebujących szybkiej autonomii humanoida w dynamicznych środowiskach wieloagentowych.
Najważniejsze
25 DOF für Competition Robotics
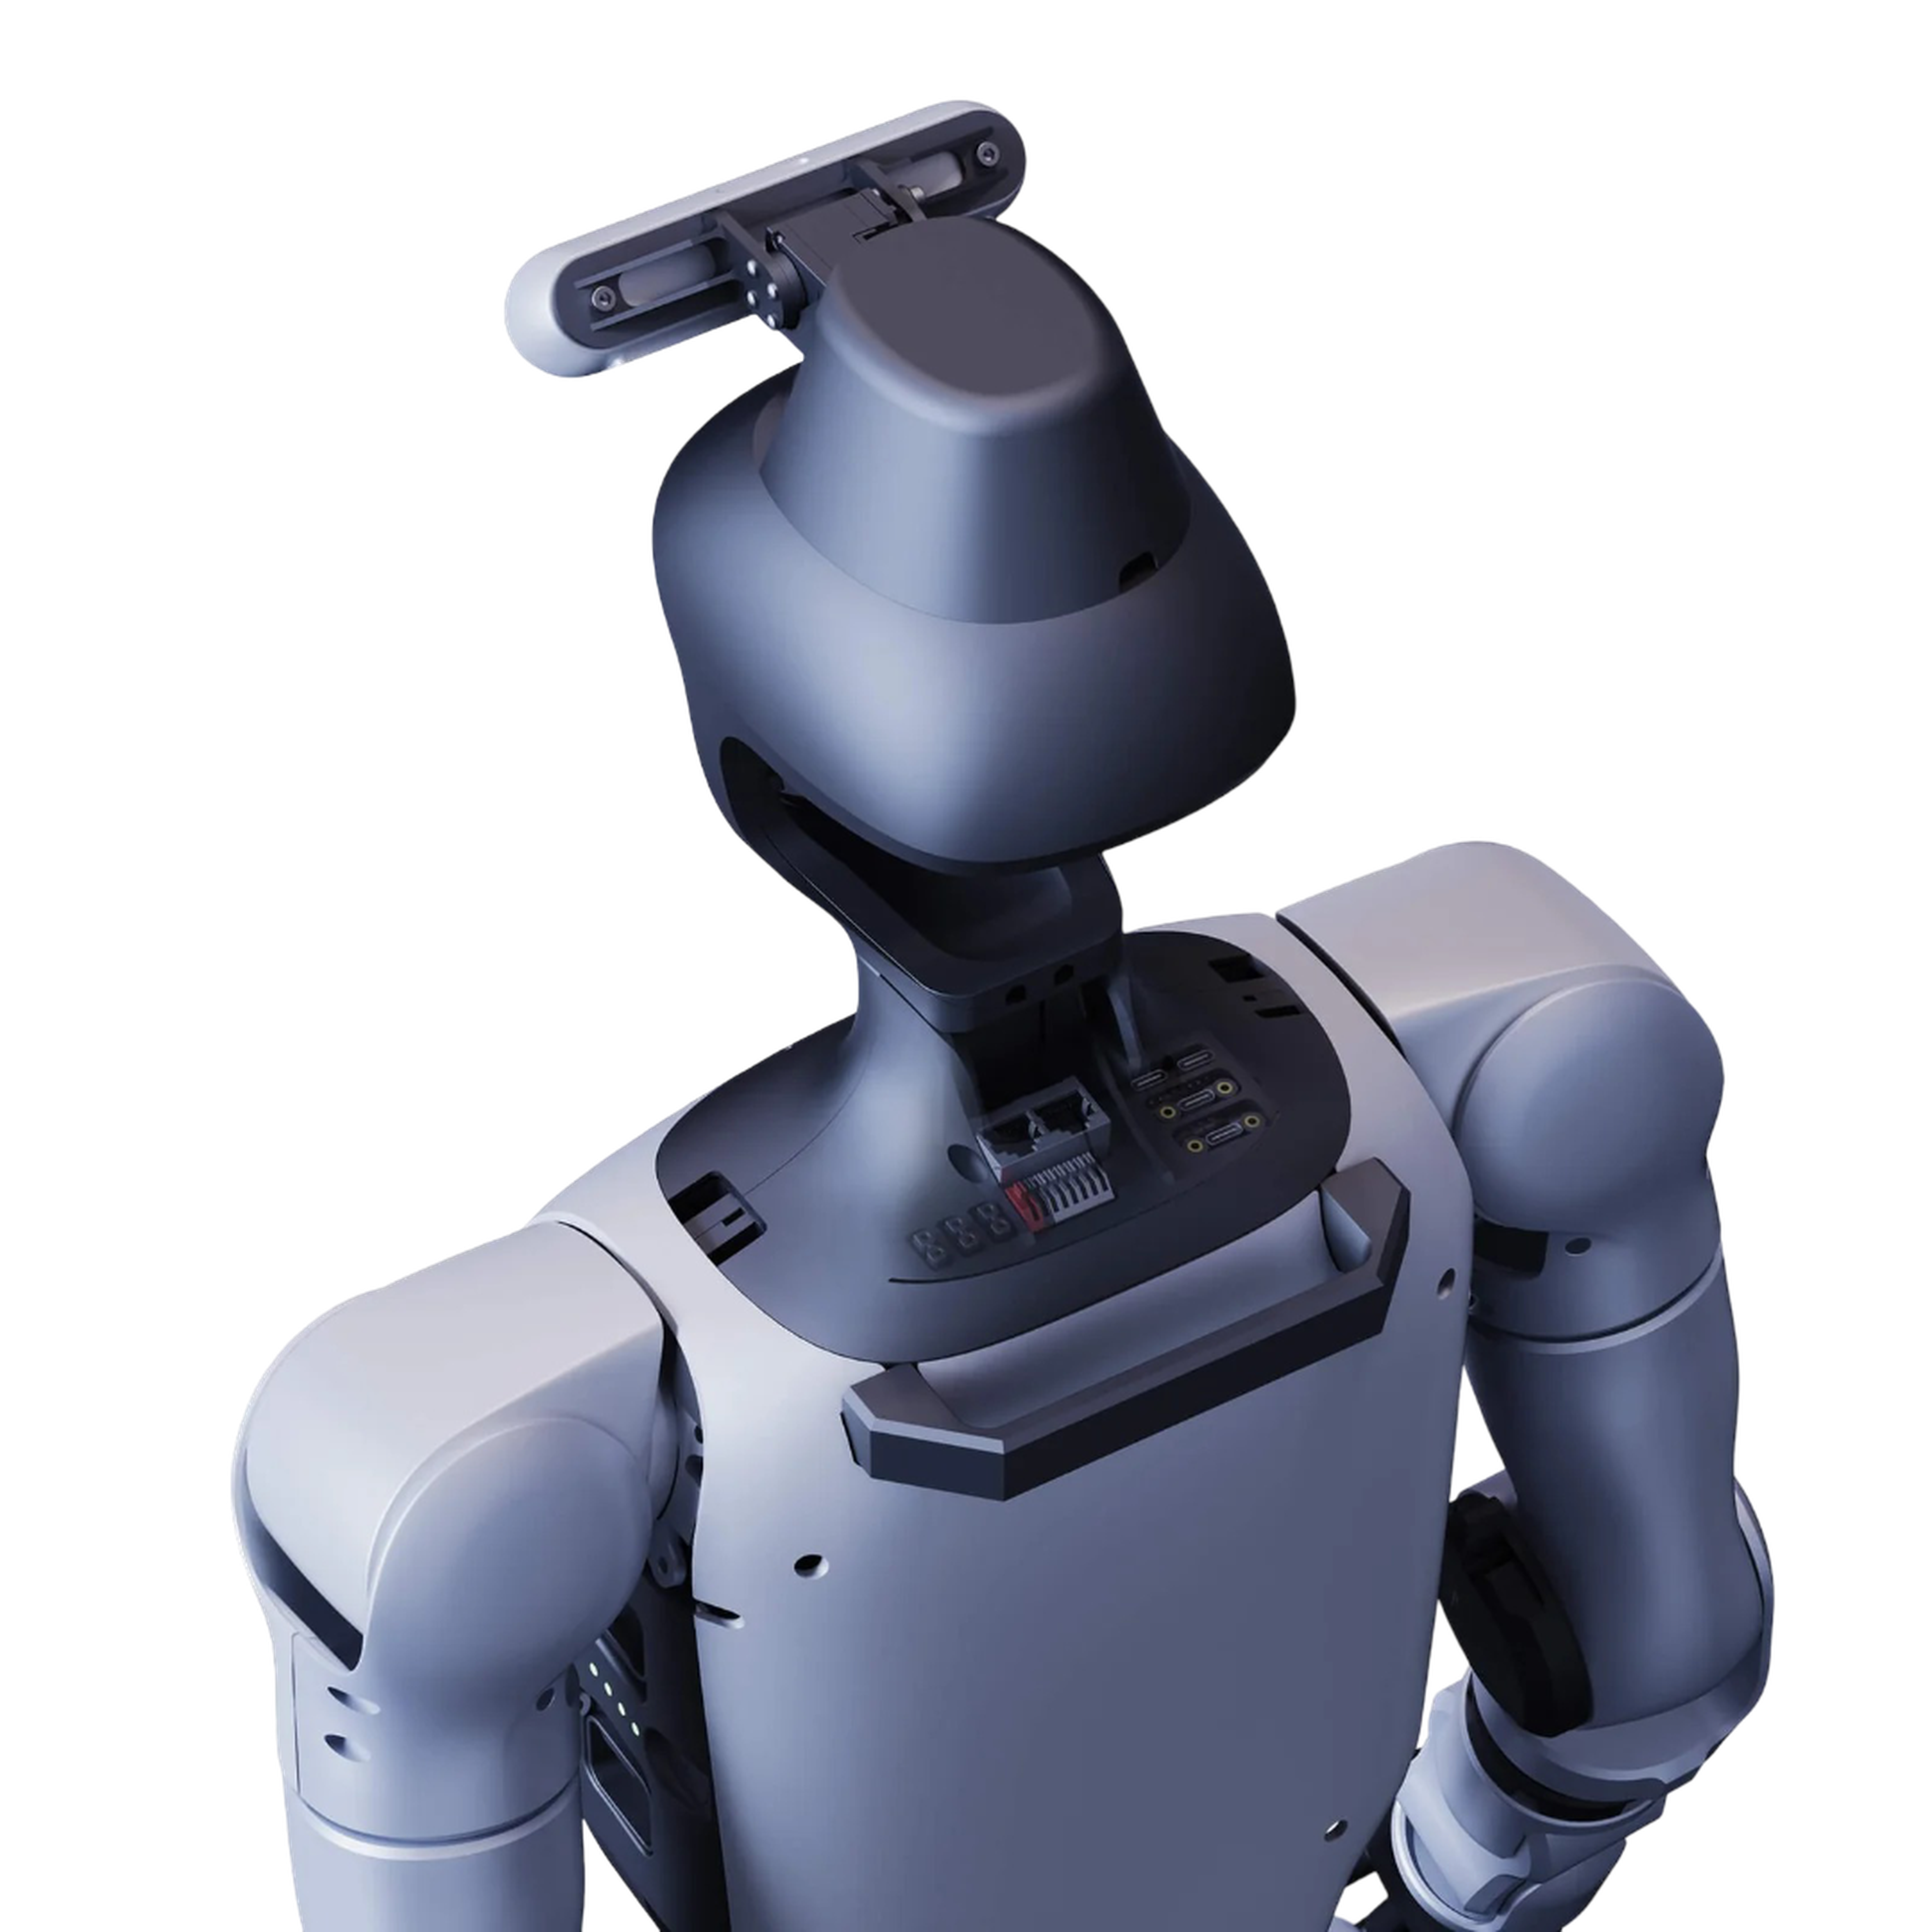
The Unitree G1 Comp features 25 degrees of freedom in the offered configuration. Each leg provides six degrees of freedom, each arm five, complemented by one waist joint and two active head joints. The humanoid stands 1,320 mm tall, with dimensions of 1,320 × 450 × 200 mm when upright. Maximum knee torque is rated at 120 N·m, while the arms support a maximum payload of approximately 3 kg. The two-axis head enables active sensor positioning during dynamic movements. With its 25-DOF configuration, the G1 Comp provides the mobility required for humanoid locomotion, robot soccer, and the development of custom motion control strategies.
100 TOPS and RoboCup SDK for Autonomous Robotics
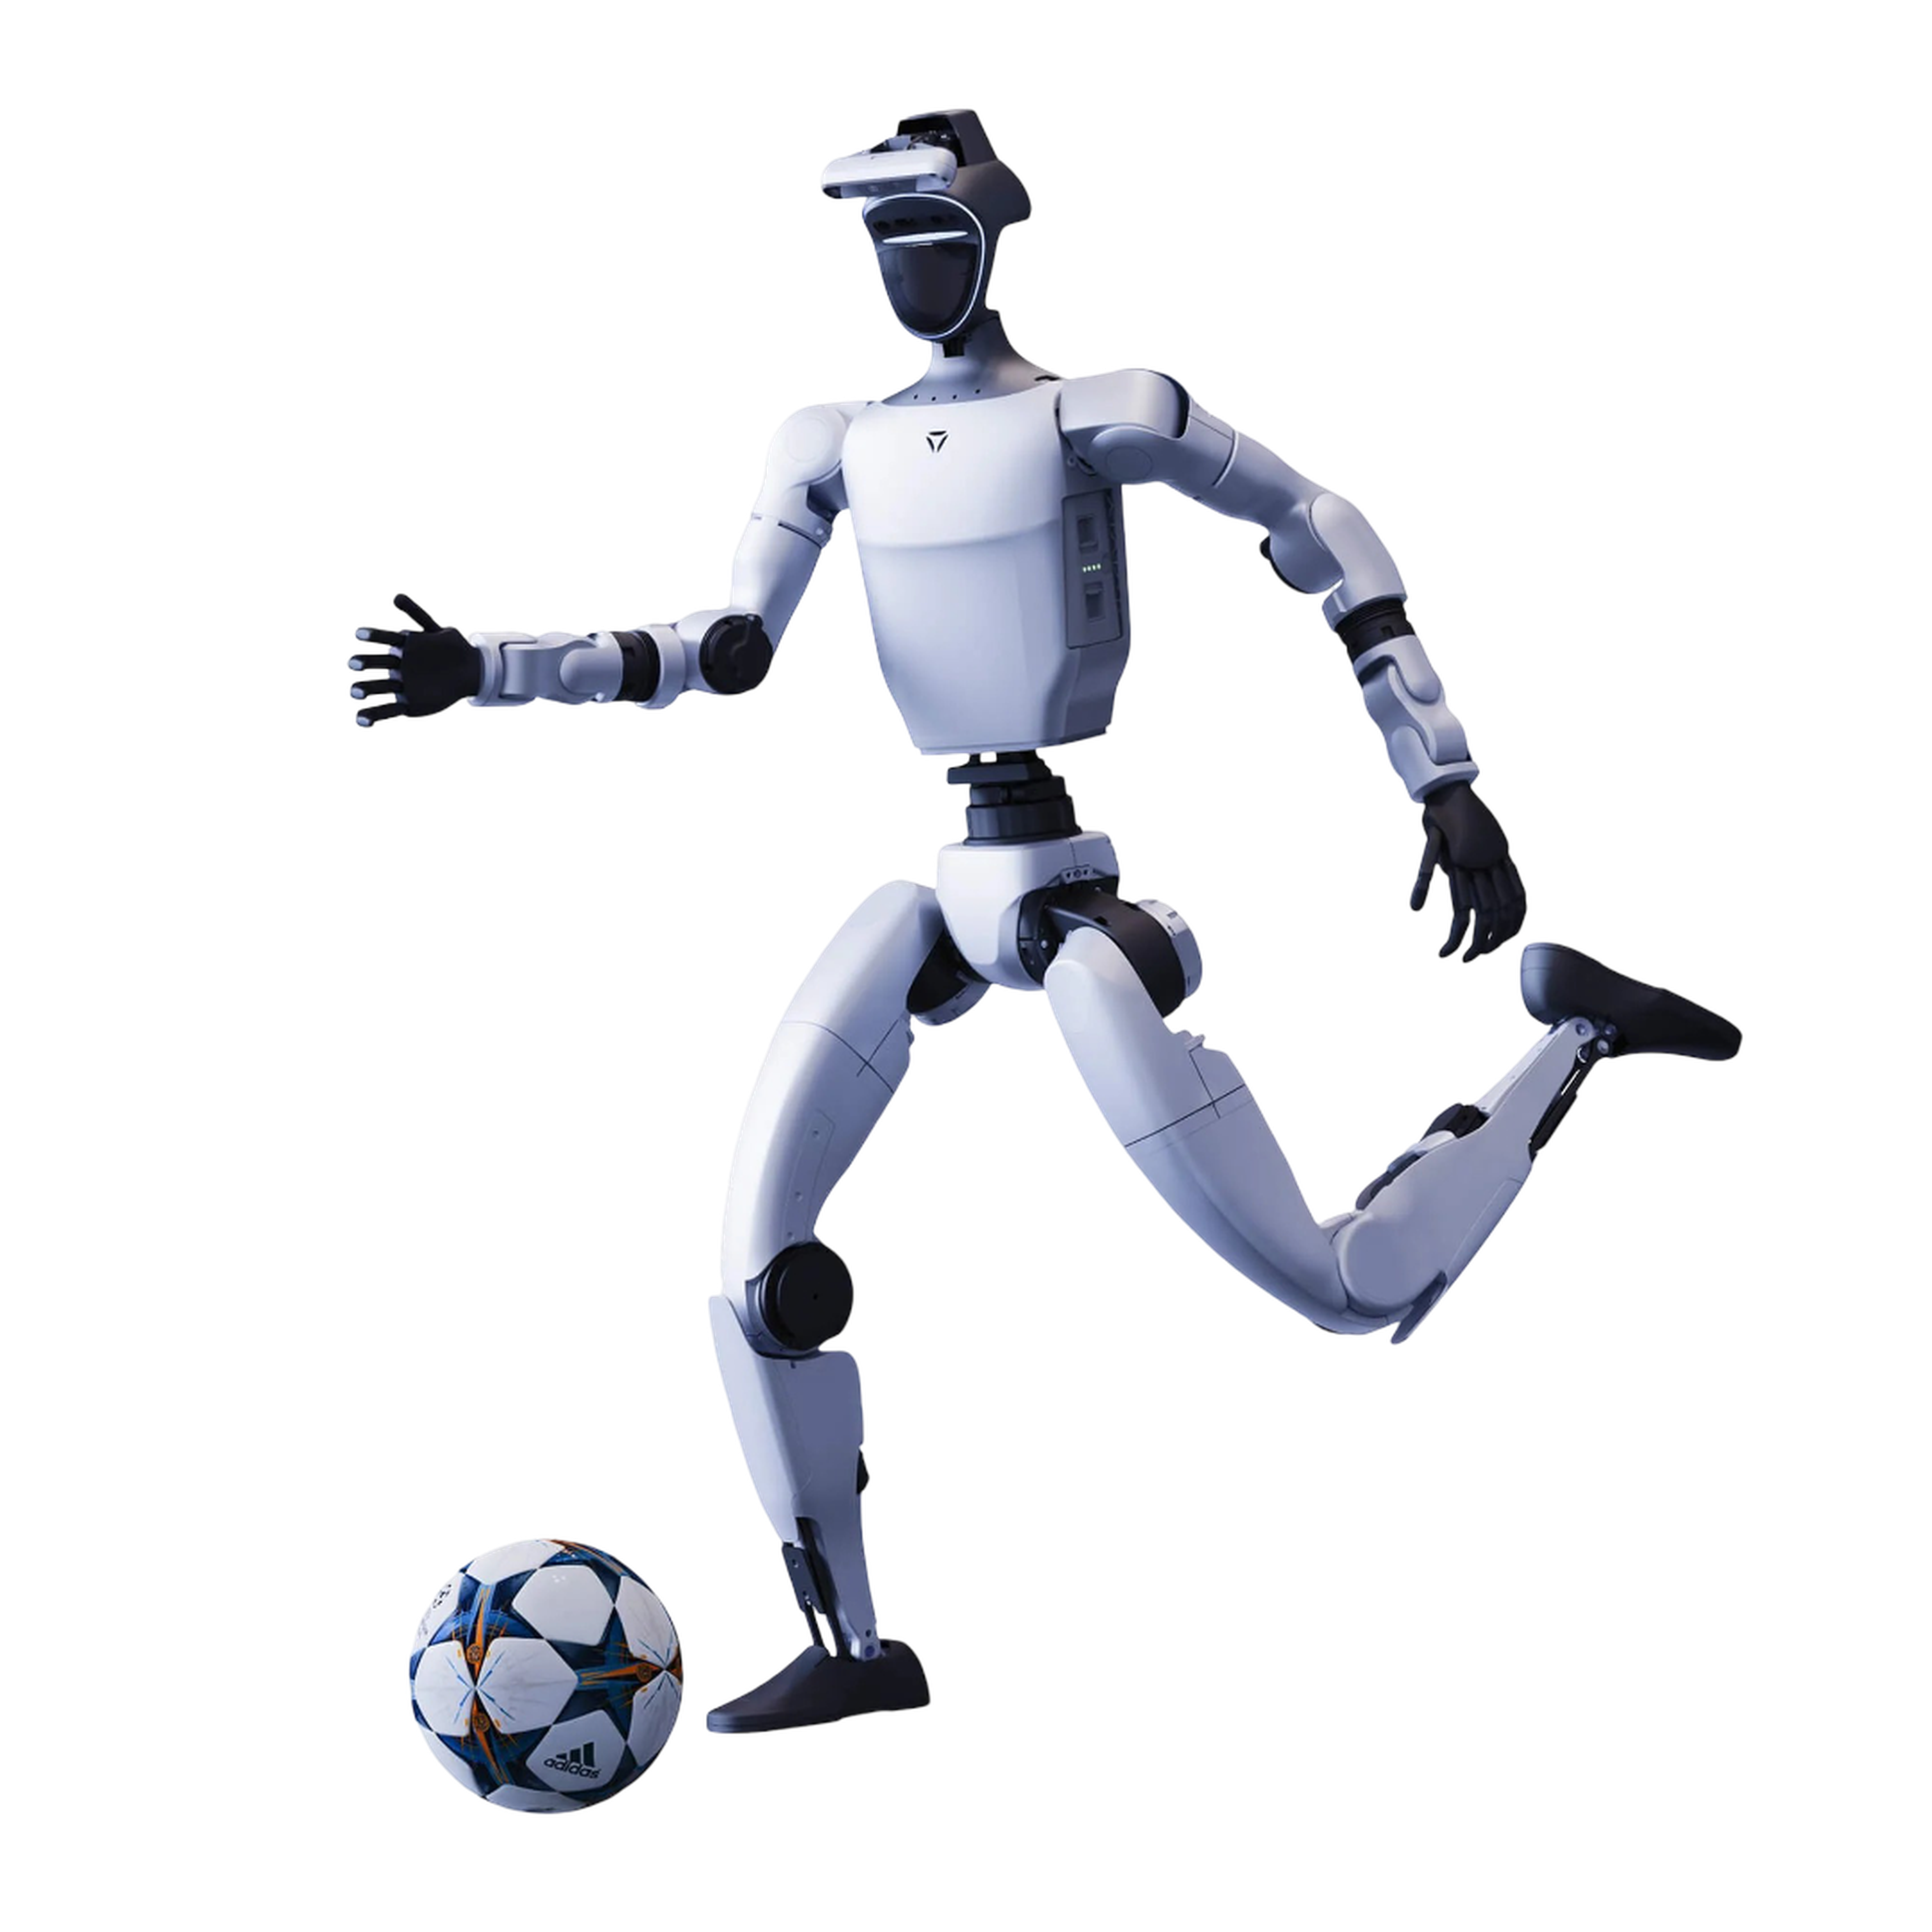
For AI and perception tasks, the Unitree G1 Comp is equipped with an NVIDIA Jetson Orin NX development computing unit delivering 100 TOPS. Unitree combines this computing platform with YOLO11 and a dedicated RoboCup SDK designed for competition-oriented robotics applications. The Visual Recognition API provides computer vision capabilities, while the Spatial Positioning API supports monocular geometric positioning and binocular depth-based positioning. Through the Motion Control API, perception and positioning data can be incorporated directly into the robot's motion control. The platform also features 3D LiDAR and a depth camera. This allows developers to combine perception, positioning, and motion control on a single robotic platform.
Reinforcement Learning and Sim2Real
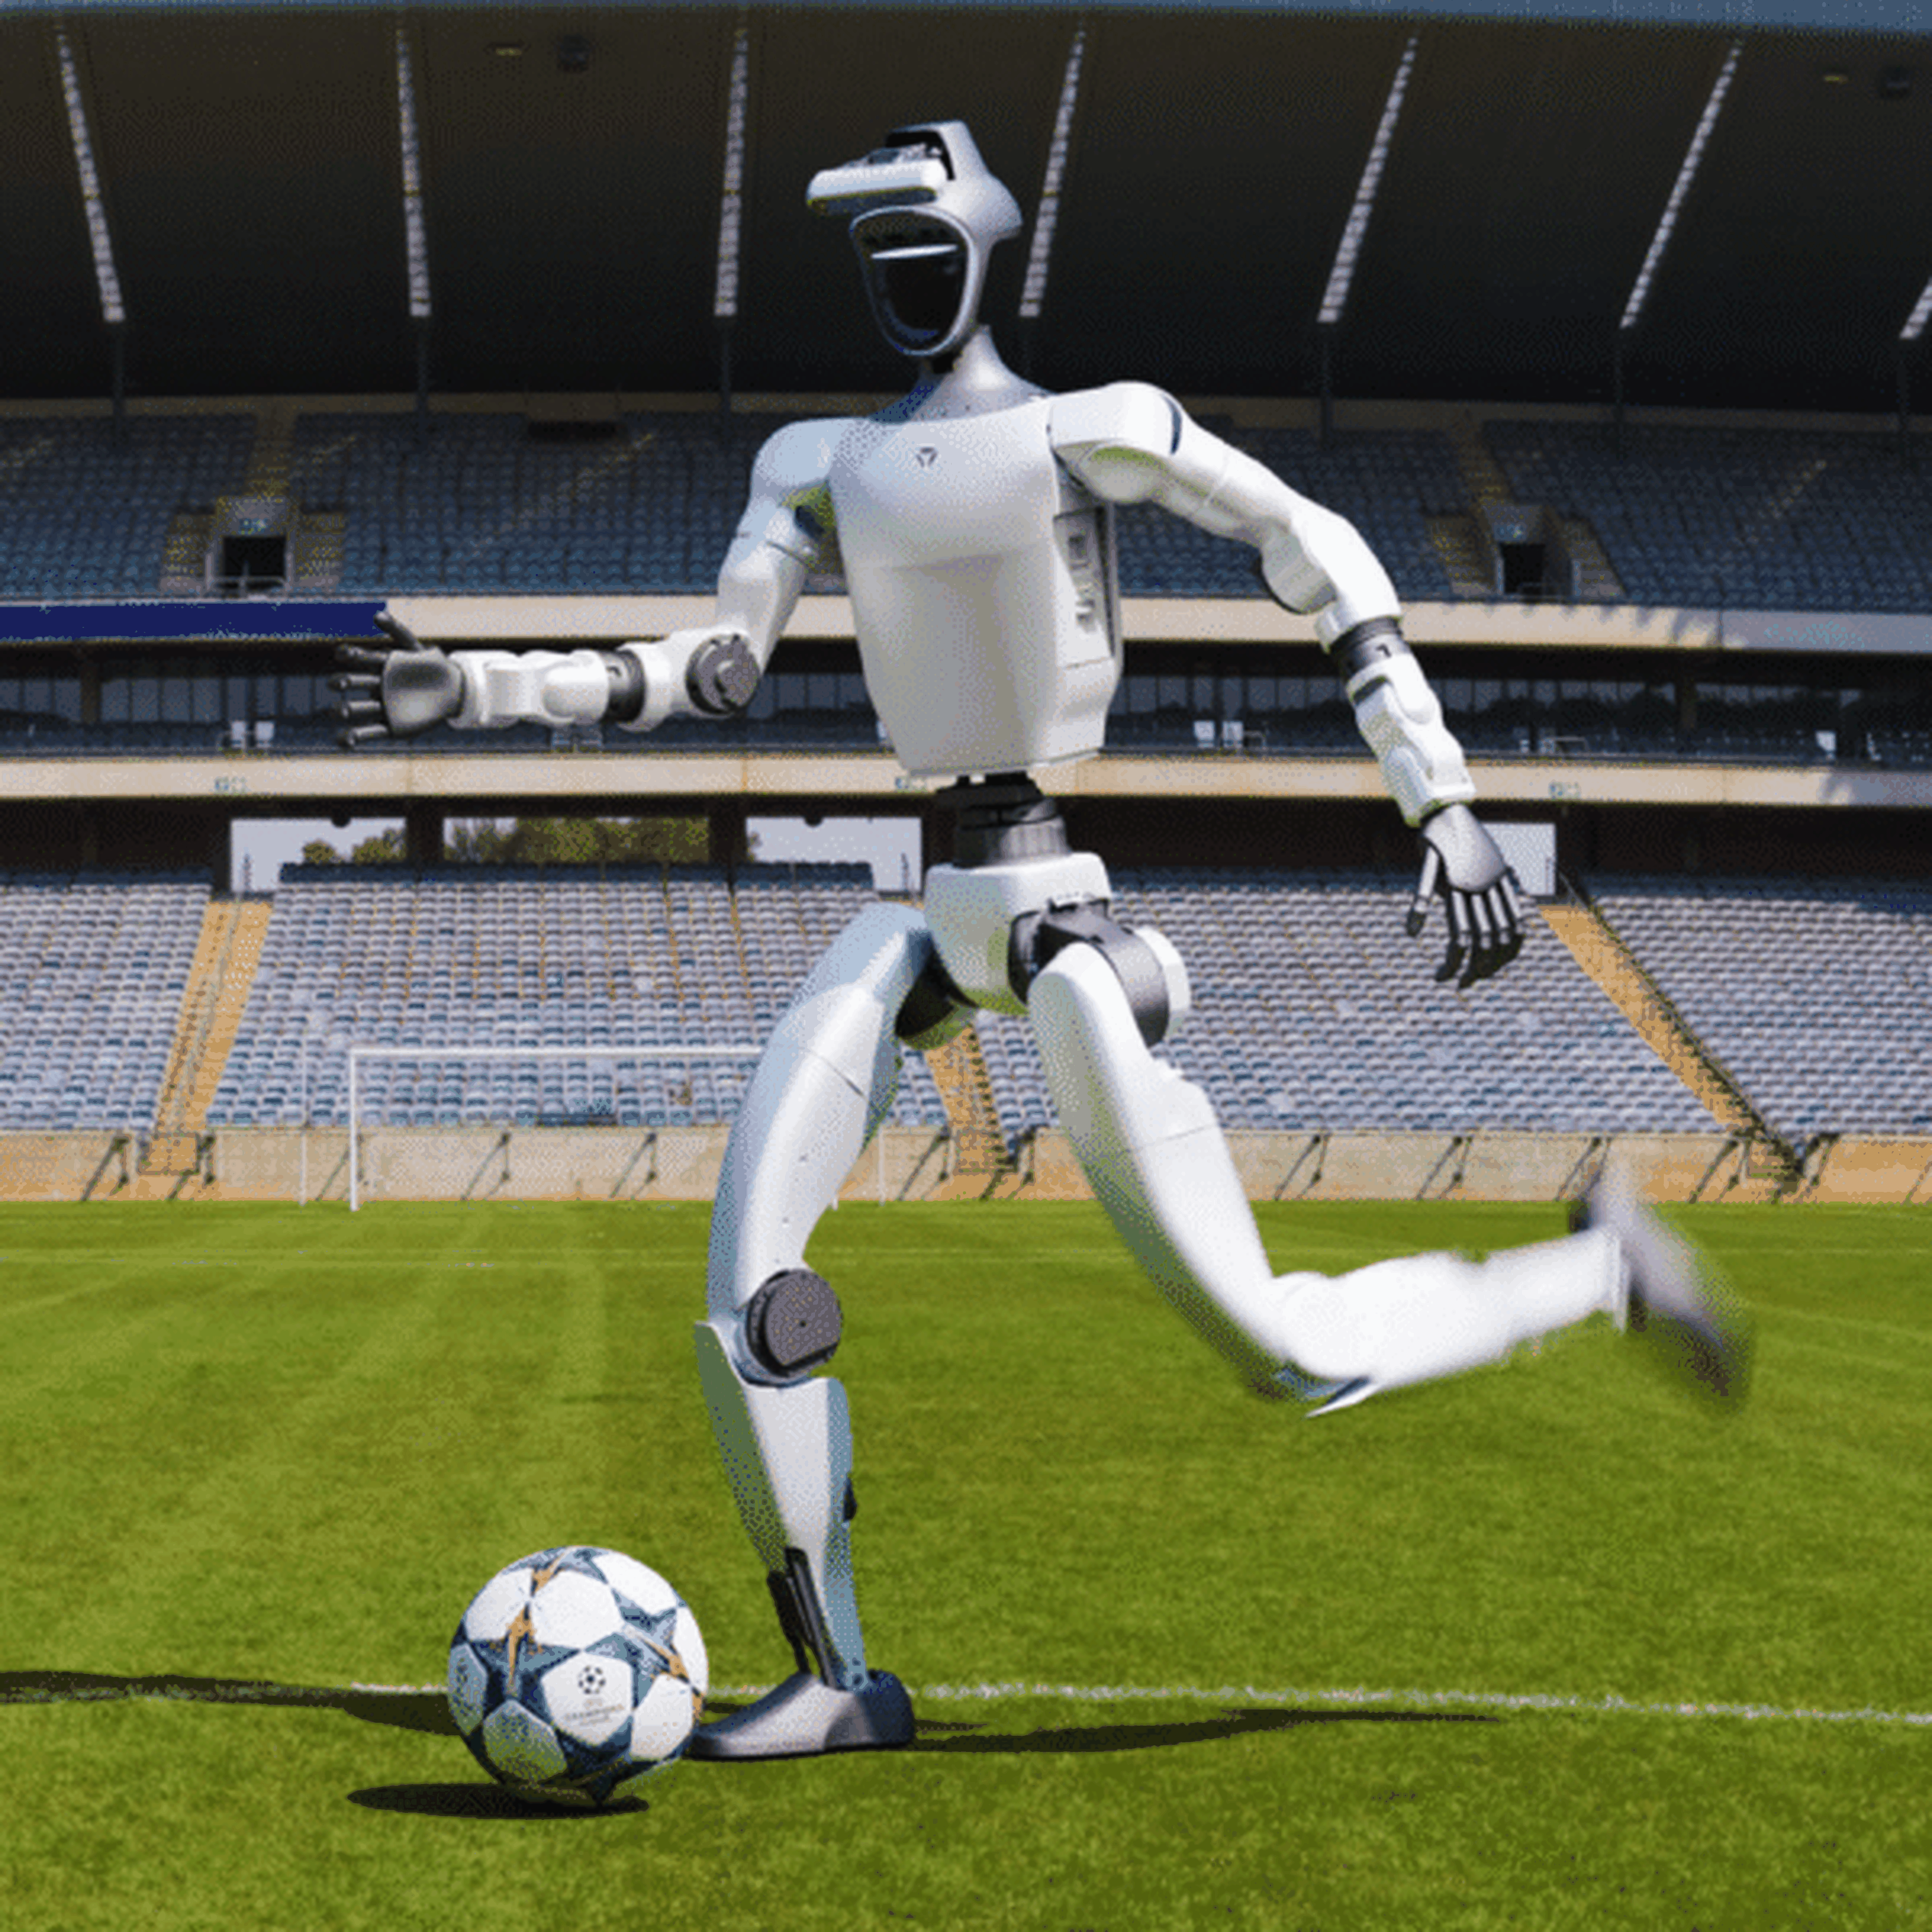
The Unitree G1 Comp supports the development of custom motion strategies using reinforcement learning. Unitree provides the unitree_rl_gym framework and supports both Isaac Gym and MuJoCo as simulation environments. The documented development workflow covers the entire process from training in simulation and Sim2Sim validation to Sim2Real deployment on the physical robot. High-level and low-level operation control interfaces, as well as a Status Service, are available for robot control. DDS communication and ROS compatibility enable integration into established robotics software environments. Configurable environments, random seeds, and training iterations support reproducible training and development workflows for humanoid locomotion and competition robotics.
Opłacalne rozwiązania zbudowane z RBTX
Zarezerwuj bezpłatną rozmowę wideo z naszymi ekspertami


